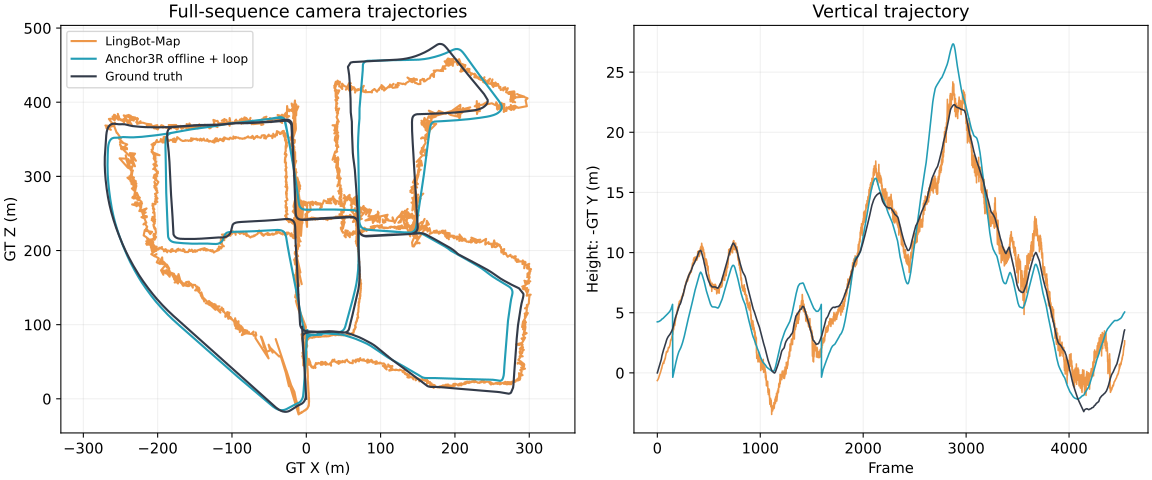
Camera trajectories
LingBot-Map
Anchor3R (offline)
Ground truthGT · meters
Preparing full-frame trajectories…
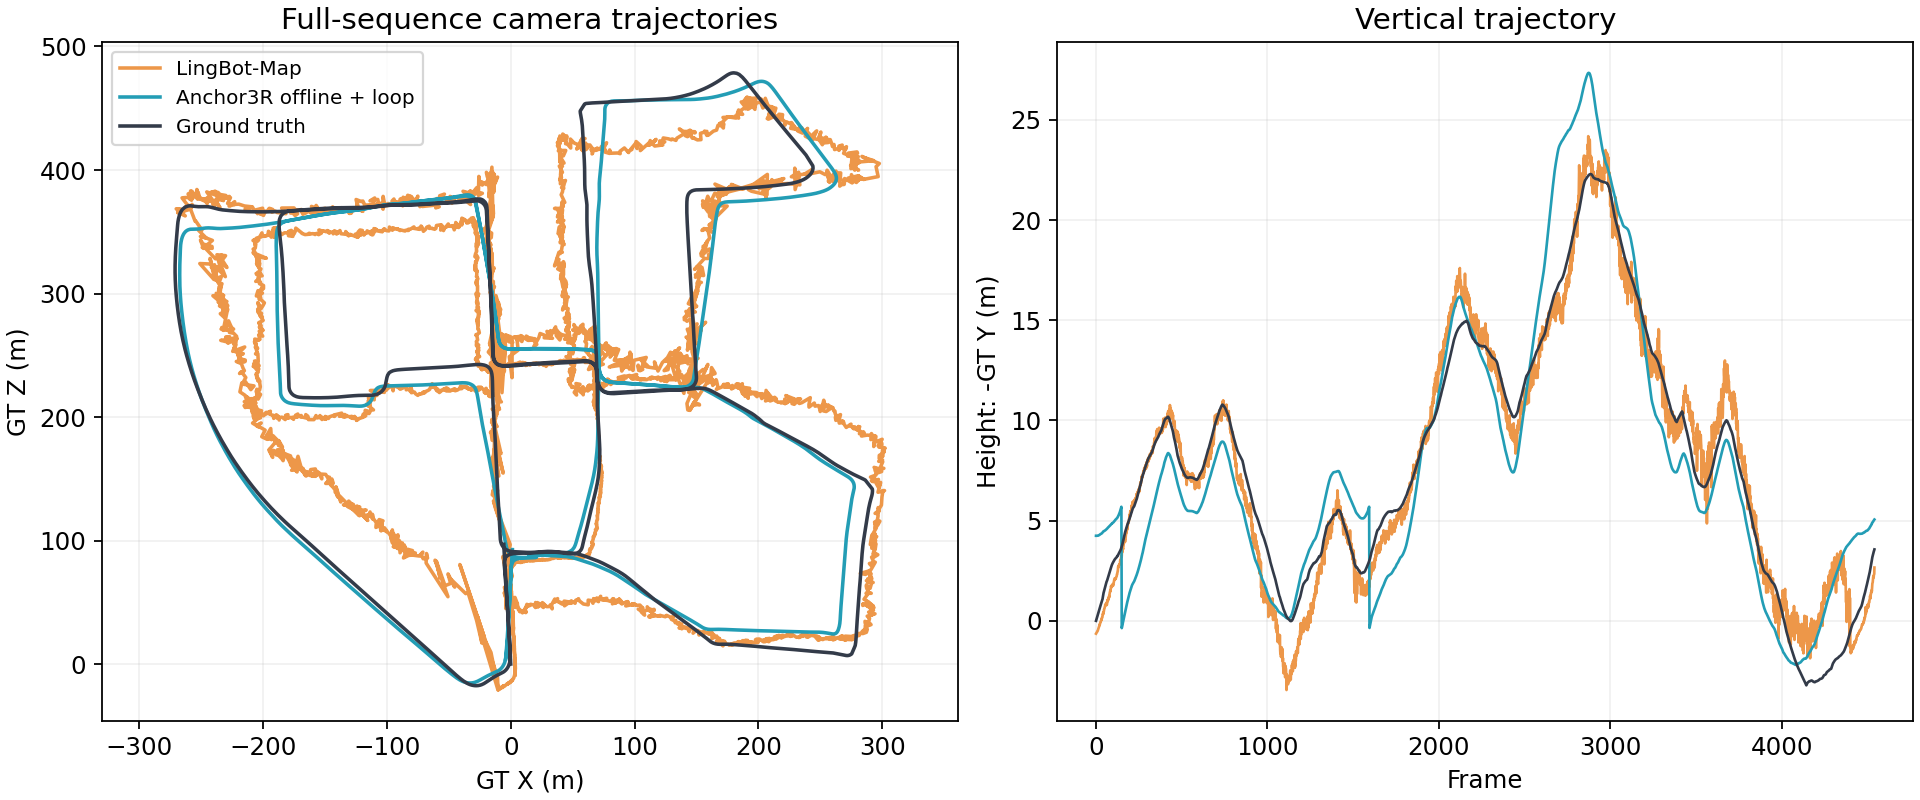
LingBot-Map and Anchor3R offline + loop on KITTI, with full-sequence GT trajectory alignment.
Drag any of the three views to rotate all · scroll / pinch to zoom · right-drag or Shift-drag to pan · shared camera, projection and metric scale · keyboard arrows to rotate, + / − to zoom, Home to reset.
Preparing full-frame trajectories…
Preparing cloud…
Preparing cloud…
Three trajectories, all frames, one global alignment per prediction.
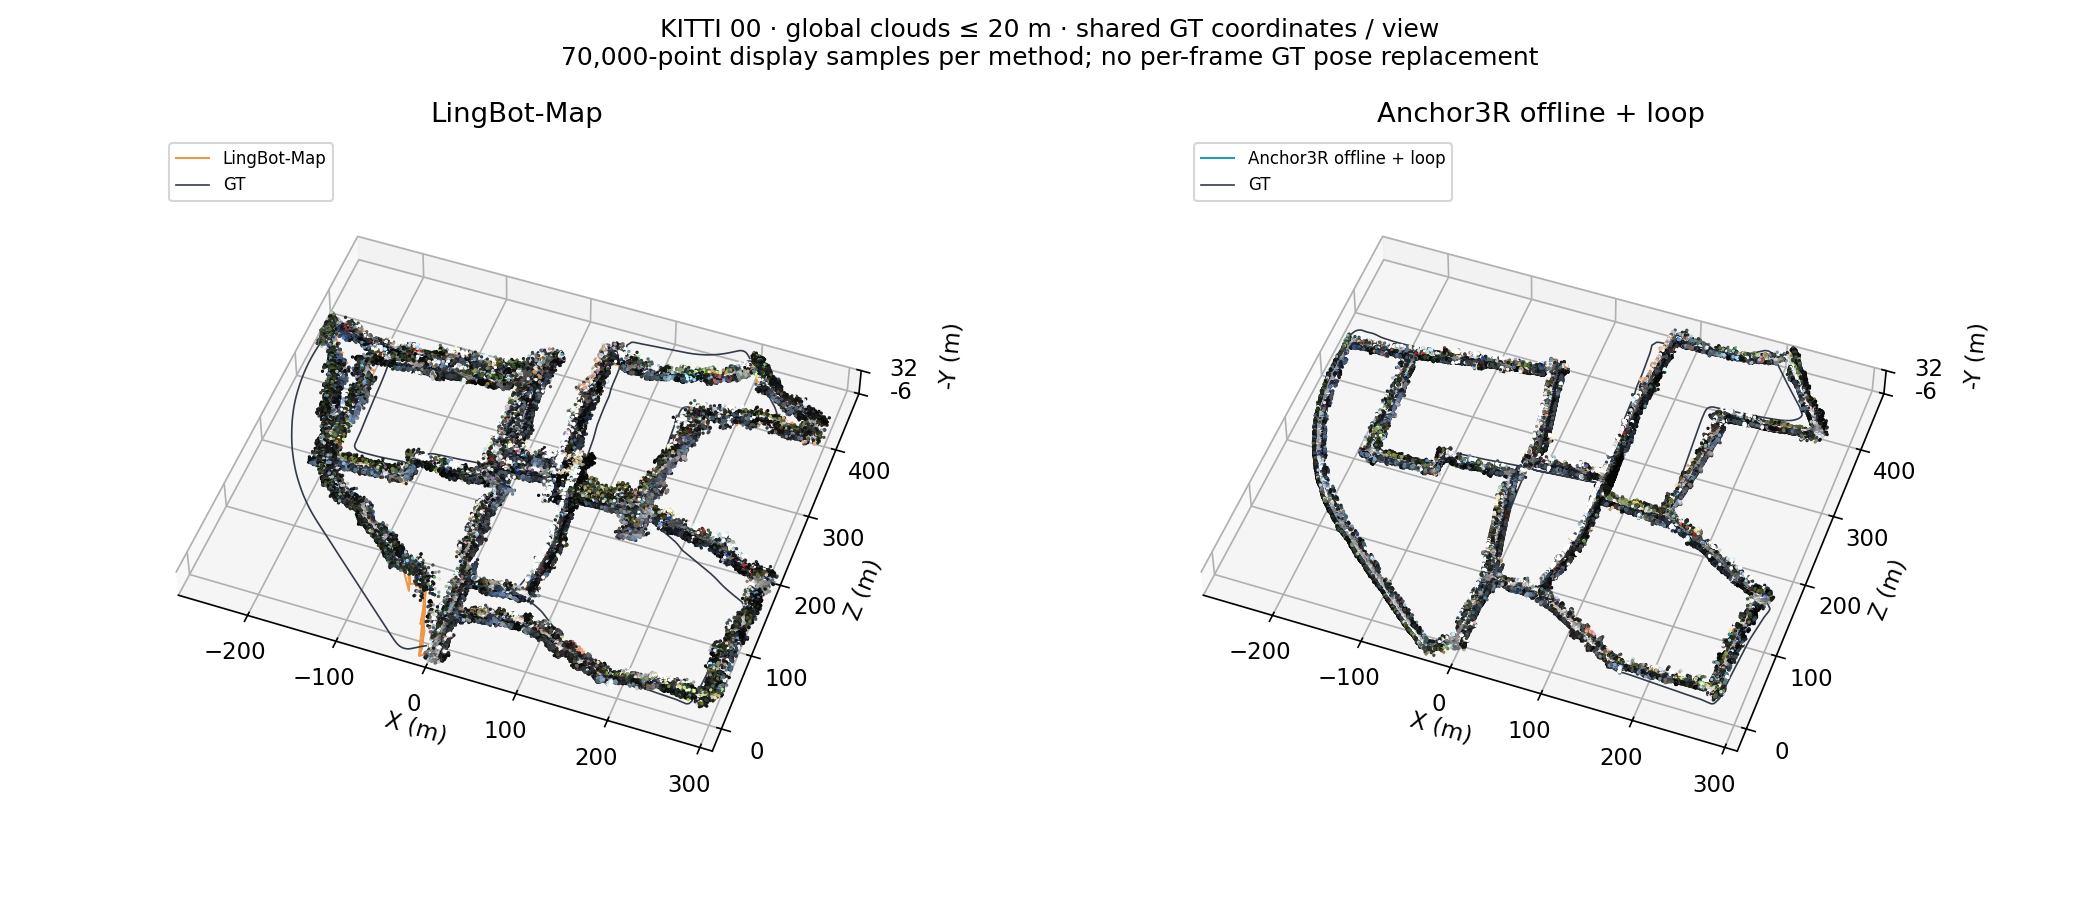
Static fallback: 70k sampled points per method, the same bounds and camera, and a fixed 20 m cutoff. The interactive controls do not change this image.
| Method | Full points | Within 20 m | Full PLY | Preview / detail |
|---|
Only the selected sequence and quality are fetched. Switching releases old GPU buffers; rendering happens on interaction rather than continuously. Raw PLY and full-resolution octree archives are intentionally not bundled into this project page.
Download alignment, sampling and source-checksum metadata